L-836.501200D
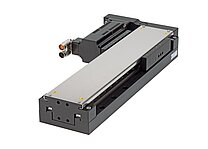
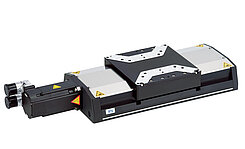
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 25 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw

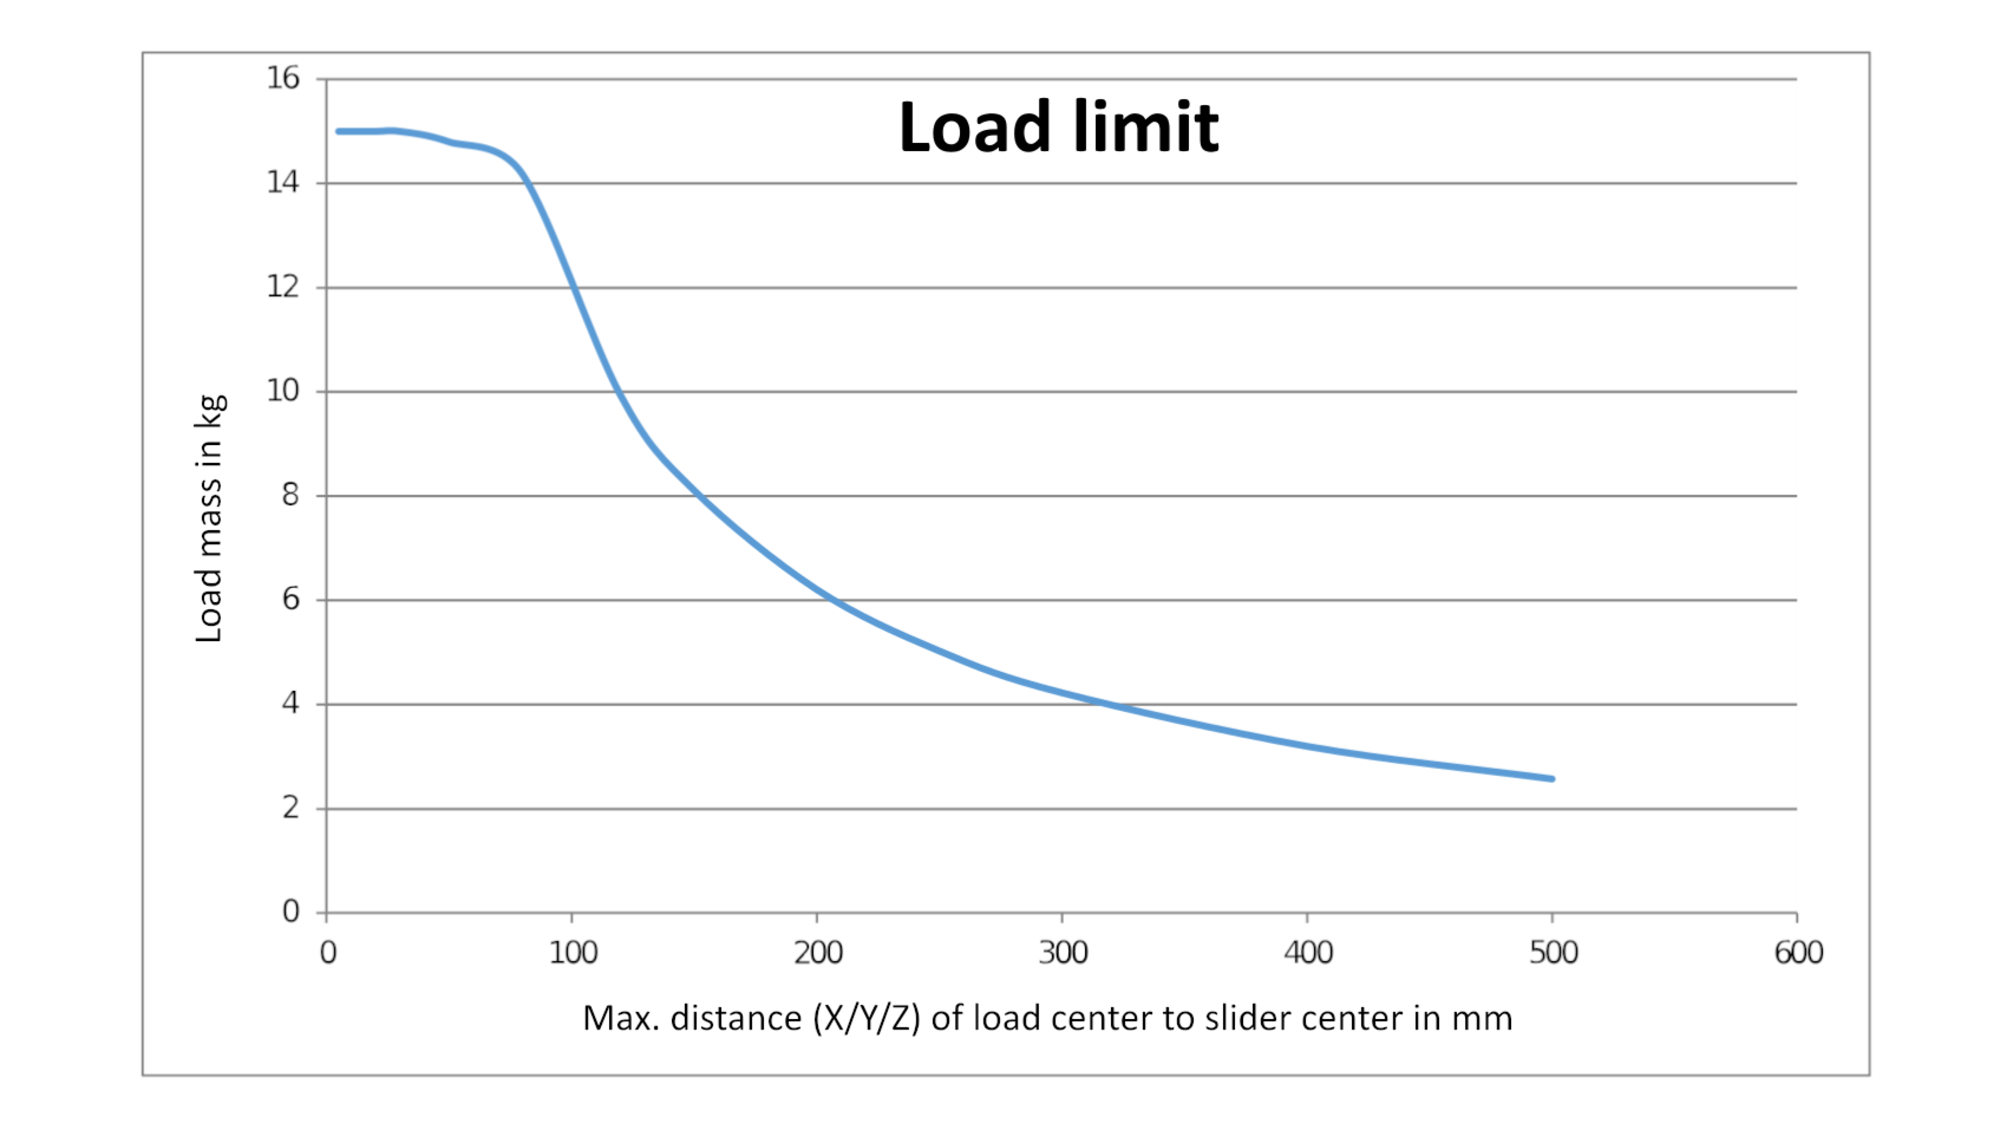
Load limit of the L-836 depending on the load mass and the distance between the load's center of gravity and the center of the slider
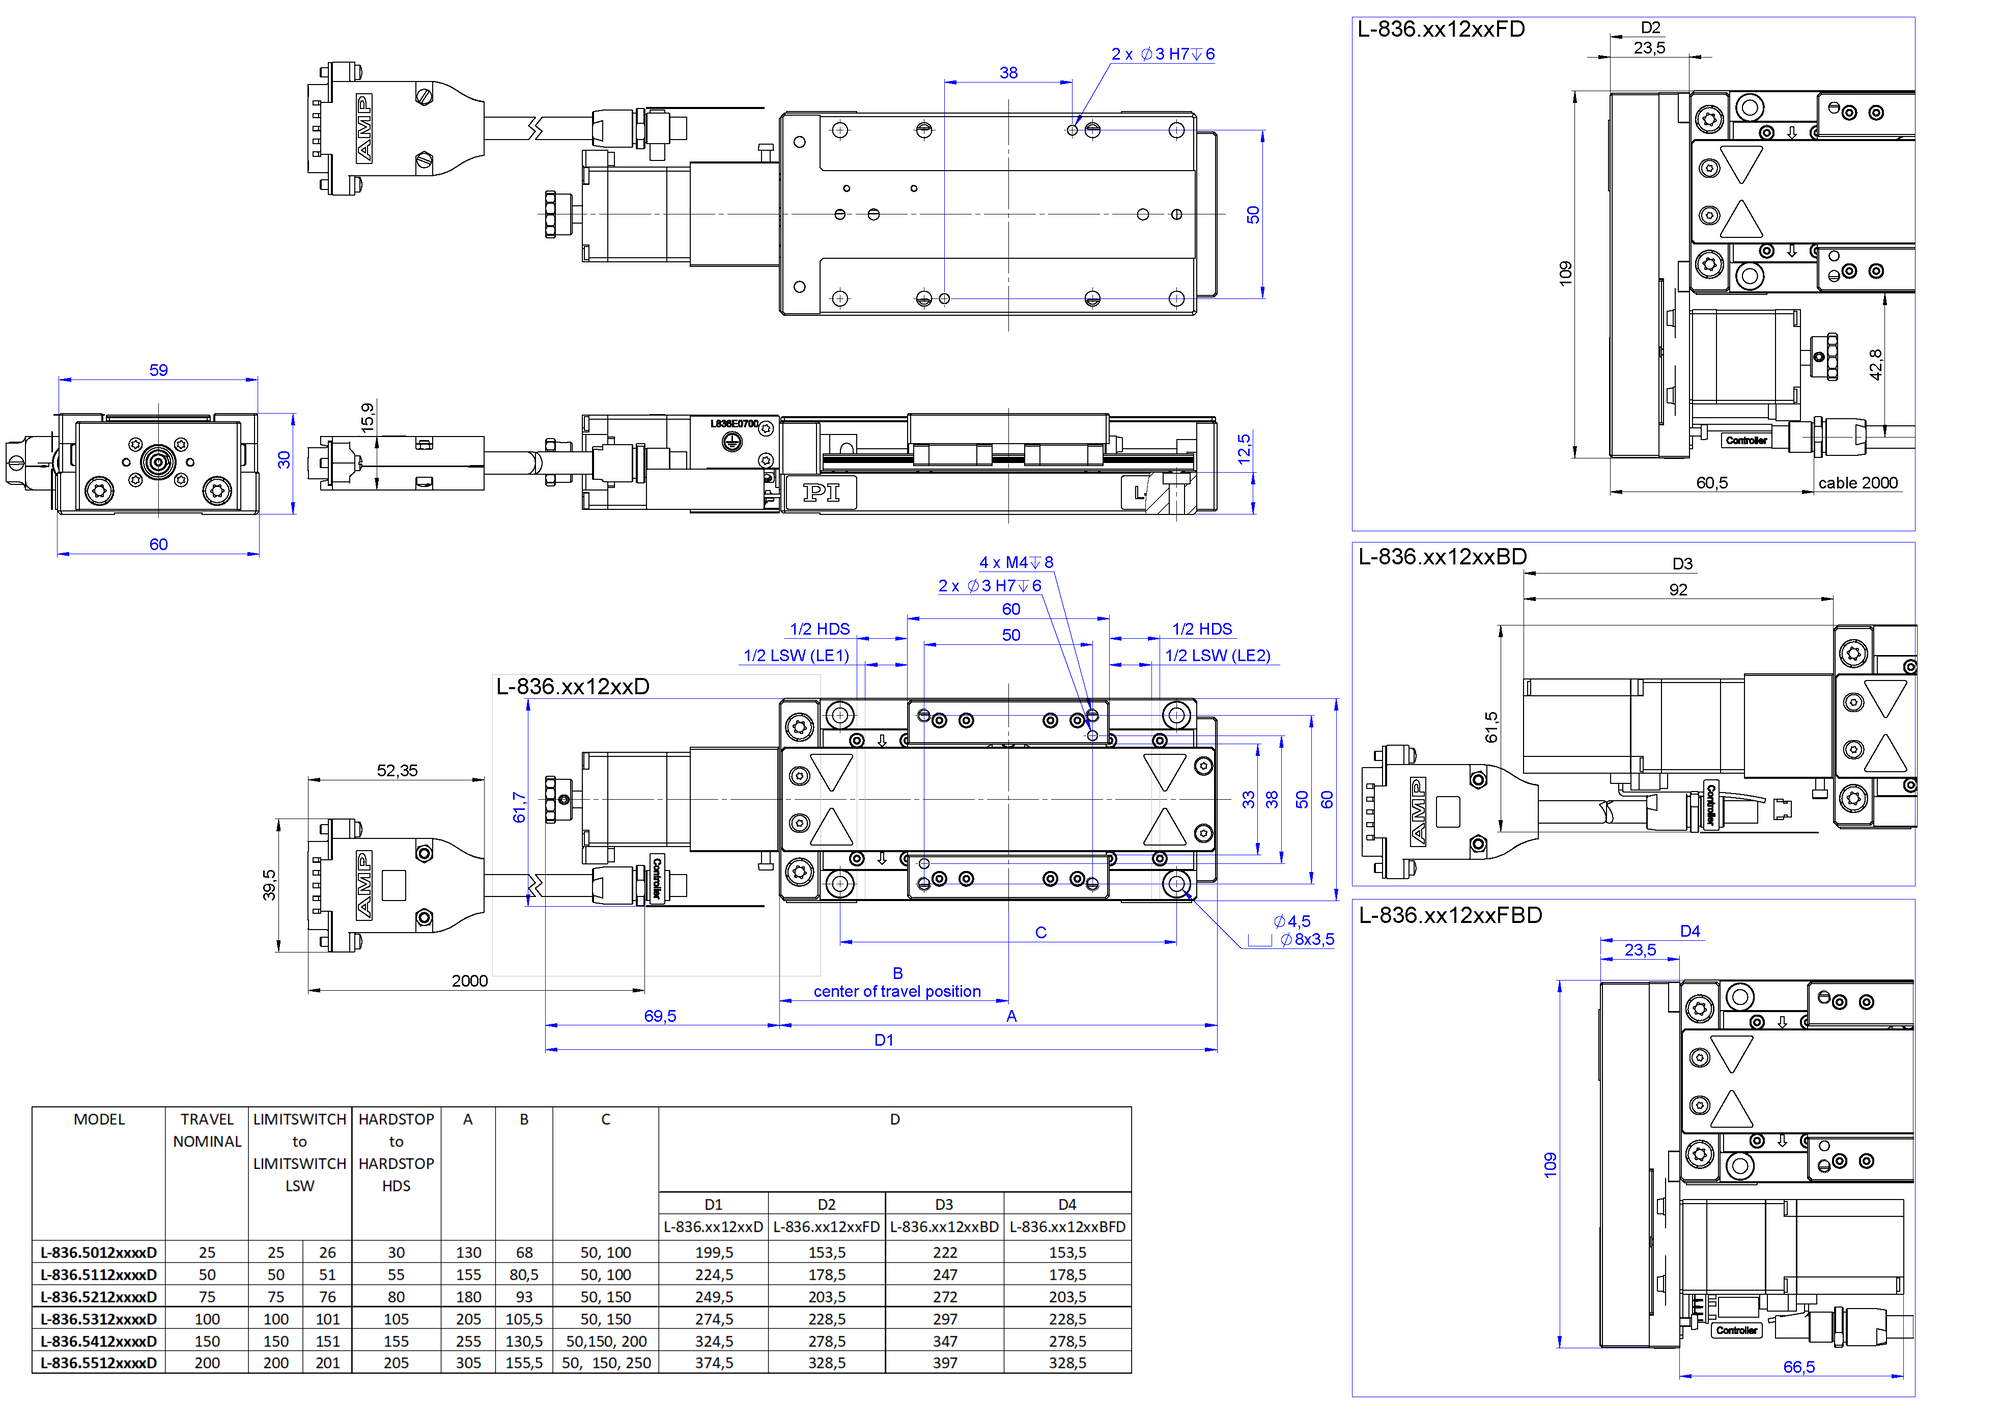
L-836.xx12xx[x[x]]D, dimensions in mm

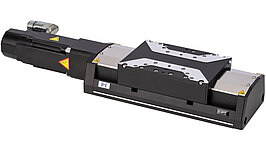
L-836.501212FD
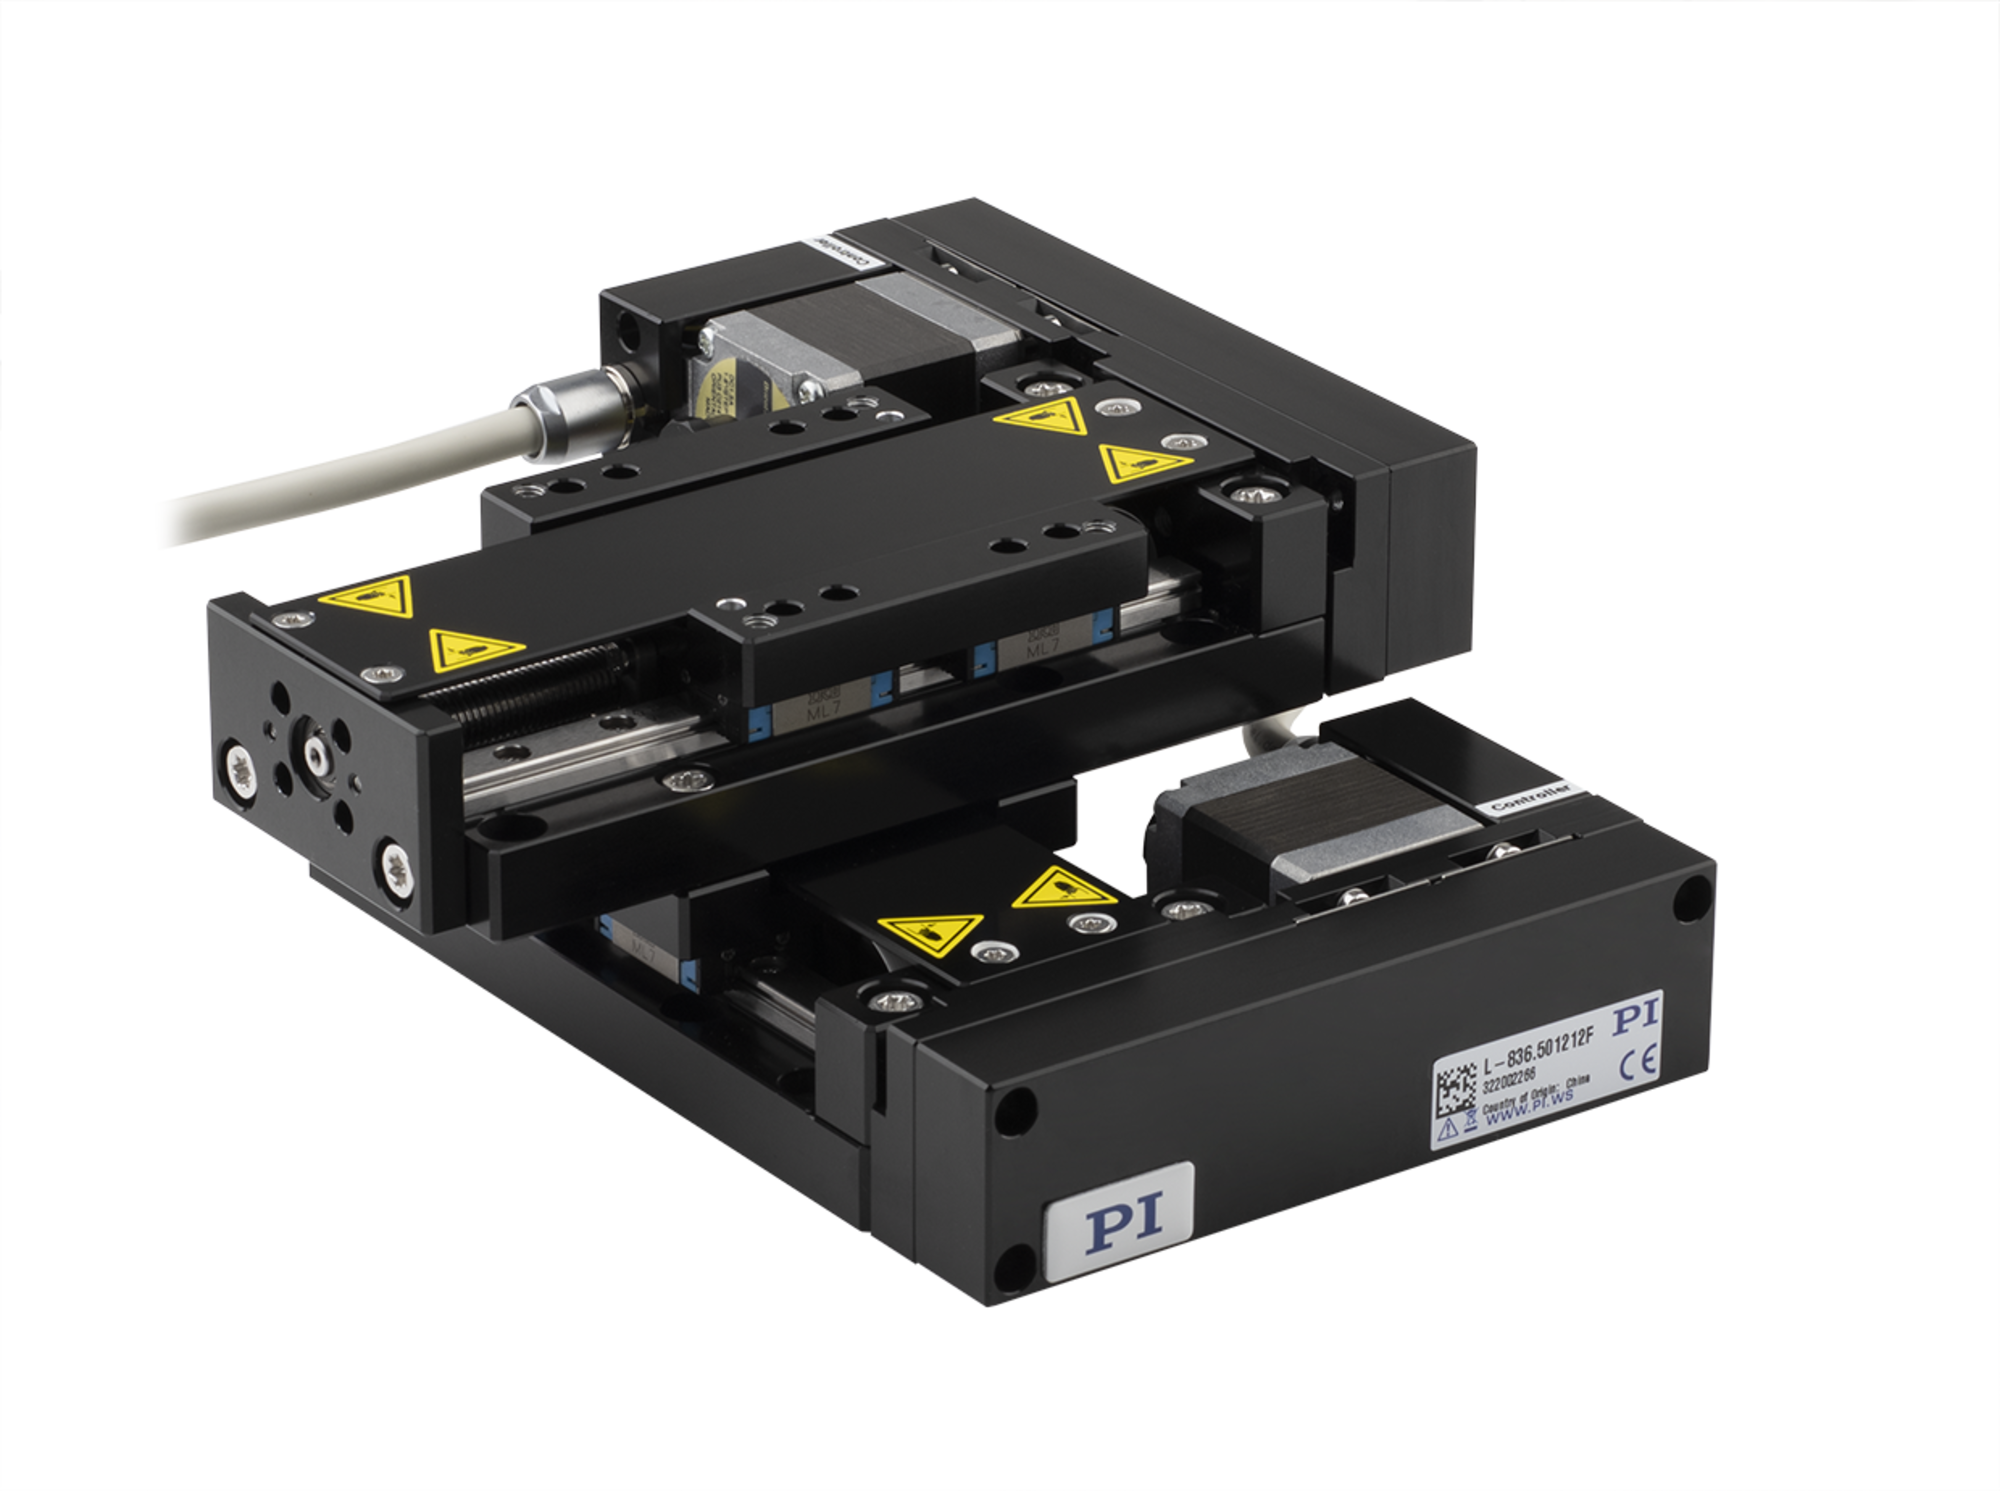
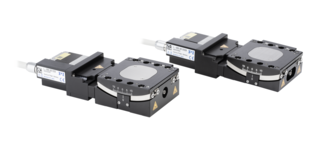
XY setup of two L-836.501212FD linear stages


The L-836 linear stage series with precision ball screw is suited for industrial applications that require high performance in compact design. High performance is achieved by high-resolution stepper motors, precision recirculating ball bearing guides, and precision linear encoders.
Application and use cases
Laser materials processing
Testing capability
Electronics manufacturing
Optical cable manufacturing
Optics assembly
Quantum photonics
Silicon photonics
Innovative manufacturing technologies
Additive manufacturing processes
Technology
Pioneering design
Optional features make the L-836 a versatile stage for a wide range of applications requiring high resolution, high repeatability, and high velocity in a compact design. The foldback option allows the motor to be mounted on the side of the stage, which further reduces the system's footprint.
Stepper motors and digital linear encoders
High-resolution 2-phase motors offer performance comparable to that of 5-phase stepper motors, but without the need for expensive drive electronics. Stages with longer travel ranges reach even higher velocities. Additional linear encoders provide high repeatability during operation.
Options
Digital incremental linear encoder
Stepper motor with foldback option for reduced overall length
Optional accessories: L-836.APx mounting bracket
Motion | Tolerance | L-836.501200D | L-836.501200FD | L-836.501212D | L-836.501212FD |
|---|---|---|---|---|---|
Active axes |
| X | X | X | X |
Travel range in X [mm] |
| 25 | 25 | 25 | 25 |
Acceleration in X, unloaded [m/s2] | max. | 2 | 2 | 2 | 2 |
Maximum velocity in X, unloaded [mm/s] |
| 40 | 40 | 40 | 40 |
Straightness error in Y (straightness) [µm] | max. | ±2 | ±2 | ±2 | ±2 |
Straightness error in Z (flatness) [µm] | max. | ±2 | ±2 | ±2 | ±2 |
Angular error around Y (pitch) [µrad] | max. | ±60 | ±60 | ±60 | ±60 |
Angular error around Z (yaw) [µrad] | max. | ±60 | ±60 | ±60 | ±60 |
Positioning | Tolerance | L-836.501200D | L-836.501200FD | L-836.501212D | L-836.501212FD |
|---|---|---|---|---|---|
Minimum incremental motion in X [µm] | max. | 0.3 | 0.4 | 0.24 | 0.24 |
Positioning accuracy in X, uncalibrated [µm] | max. | ±6 | ±6 | ±6 | ±6 |
Bidirectional repeatability in X [µm] | max. | 2 | 4 | 0.8 | 0.8 |
Reference switch |
| Hall effect | Hall effect | Hall effect | Hall effect |
Limit switch |
| Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN |
Integrated sensor |
| — | — | Incremental linear encoder | Incremental linear encoder |
Sensor signal |
| — | — | A/B quadrature, RS-422 | A/B quadrature, RS-422 |
Sensor signal period [µm] |
| — | — | 80 | 80 |
Sensor resolution [nm] 1) |
| — | — | 80 | 80 |
Drive properties | Tolerance | L-836.501200D | L-836.501200FD | L-836.501212D | L-836.501212FD |
|---|---|---|---|---|---|
Drive type |
| 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor |
Operating voltage [V] |
| 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 |
Nominal current, RMS [A] | typ. | 1.5 | 1.5 | 1.5 | 1.5 |
Maximum power consumption [W] |
| 7 | 7 | 8 | 8 |
Motor resolution [full steps/U] |
| 200 | 200 | 200 | 200 |
Drive force in X [N] | typ. | 75 | 75 | 75 | 75 |
Resistance phase-phase [Ω] 2) | typ. | 1.18 | 1.18 | 1.18 | 1.18 |
Inductance phase-phase [mH] |
| 0.96 | 0.96 | 0.96 | 0.96 |
Mechanical properties | Tolerance | L-836.501200D | L-836.501200FD | L-836.501212D | L-836.501212FD |
|---|---|---|---|---|---|
Permissible push force in Y [N] | max. | 50 | 50 | 50 | 50 |
Permissible push force in Z [N] | max. | 150 | 150 | 150 | 150 |
Permissible torque in θX [Nm] | max. | 15 | 15 | 15 | 15 |
Permissible torque in θY [Nm] | max. | 15 | 15 | 15 | 15 |
Permissible torque in θZ [Nm] | max. | 10 | 10 | 10 | 10 |
Holding force in X, passive [N] |
| — | — | — | — |
Moved mass in X, unloaded [g] |
| 130 | 130 | 140 | 140 |
Drive screw type |
| Ball screw | Ball screw | Ball screw | Ball screw |
Drive screw pitch [mm] |
| 1 | 1 | 1 | 1 |
Guide |
| Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide |
Overall mass [g] |
| 710 | 770 | 720 | 780 |
Material |
| Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel |
Holding brake |
| — | — | — | — |
Miscellaneous | L-836.501200D | L-836.501200FD | L-836.501212D | L-836.501212FD |
|---|---|---|---|---|
Operating temperature range [°C] | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 |
Connector | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) |
Recommended controllers/drivers | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller |
Motion | Tolerance | L-836.511200D | L-836.511200FD | L-836.511212D | L-836.511212FD |
|---|---|---|---|---|---|
Active axes |
| X | X | X | X |
Travel range in X [mm] |
| 50 | 50 | 50 | 50 |
Acceleration in X, unloaded [m/s2] | max. | 2 | 2 | 2 | 2 |
Maximum velocity in X, unloaded [mm/s] |
| 40 | 40 | 40 | 40 |
Straightness error in Y (straightness) [µm] | max. | ±2 | ±2 | ±2 | ±2 |
Straightness error in Z (flatness) [µm] | max. | ±2 | ±2 | ±2 | ±2 |
Angular error around Y (pitch) [µrad] | max. | ±100 | ±100 | ±100 | ±100 |
Angular error around Z (yaw) [µrad] | max. | ±100 | ±100 | ±100 | ±100 |
Positioning | Tolerance | L-836.511200D | L-836.511200FD | L-836.511212D | L-836.511212FD |
|---|---|---|---|---|---|
Minimum incremental motion in X [µm] | max. | 0.3 | 0.4 | 0.24 | 0.24 |
Positioning accuracy in X, uncalibrated [µm] | max. | ±13 | ±13 | ±13 | ±13 |
Bidirectional repeatability in X [µm] | max. | 2 | 4 | 0.8 | 0.8 |
Reference switch |
| Hall effect | Hall effect | Hall effect | Hall effect |
Limit switch |
| Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN |
Integrated sensor |
| — | — | Incremental linear encoder | Incremental linear encoder |
Sensor signal |
| — | — | A/B quadrature, RS-422 | A/B quadrature, RS-422 |
Sensor signal period [µm] |
| — | — | 80 | 80 |
Sensor resolution [nm] 1) |
| — | — | 80 | 80 |
Drive properties | Tolerance | L-836.511200D | L-836.511200FD | L-836.511212D | L-836.511212FD |
|---|---|---|---|---|---|
Drive type |
| 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor |
Operating voltage [V] |
| 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 |
Nominal current, RMS [A] | typ. | 1.5 | 1.5 | 1.5 | 1.5 |
Maximum power consumption [W] |
| 7 | 7 | 8 | 8 |
Motor resolution [full steps/U] |
| 200 | 200 | 200 | 200 |
Drive force in X [N] | typ. | 75 | 75 | 75 | 75 |
Resistance phase-phase [Ω] 2) | typ. | 1.18 | 1.18 | 1.18 | 1.18 |
Inductance phase-phase [mH] |
| 0.96 | 0.96 | 0.96 | 0.96 |
Mechanical properties | Tolerance | L-836.511200D | L-836.511200FD | L-836.511212D | L-836.511212FD |
|---|---|---|---|---|---|
Permissible push force in Y [N] | max. | 50 | 50 | 50 | 50 |
Permissible push force in Z [N] | max. | 150 | 150 | 150 | 150 |
Permissible torque in θX [Nm] | max. | 15 | 15 | 15 | 15 |
Permissible torque in θY [Nm] | max. | 15 | 15 | 15 | 15 |
Permissible torque in θZ [Nm] | max. | 10 | 10 | 10 | 10 |
Holding force in X, passive [N] |
| — | — | — | — |
Moved mass in X, unloaded [g] |
| 130 | 130 | 140 | 140 |
Drive screw type |
| Ball screw | Ball screw | Ball screw | Ball screw |
Drive screw pitch [mm] |
| 1 | 1 | 1 | 1 |
Guide |
| Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide |
Overall mass [g] |
| 770 | 830 | 780 | 840 |
Material |
| Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel |
Holding brake |
| — | — | — | — |
Miscellaneous | L-836.511200D | L-836.511200FD | L-836.511212D | L-836.511212FD |
|---|---|---|---|---|
Operating temperature range [°C] | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 |
Connector | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) |
Recommended controllers/drivers | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller |
Motion | Tolerance | L-836.521200D | L-836.521200FD | L-836.521212D | L-836.521212FD |
|---|---|---|---|---|---|
Active axes |
| X | X | X | X |
Travel range in X [mm] |
| 75 | 75 | 75 | 75 |
Acceleration in X, unloaded [m/s2] | max. | 2 | 2 | 2 | 2 |
Maximum velocity in X, unloaded [mm/s] |
| 40 | 40 | 40 | 40 |
Straightness error in Y (straightness) [µm] | max. | ±2 | ±2 | ±2 | ±2 |
Straightness error in Z (flatness) [µm] | max. | ±2 | ±2 | ±2 | ±2 |
Angular error around Y (pitch) [µrad] | max. | ±120 | ±120 | ±120 | ±120 |
Angular error around Z (yaw) [µrad] | max. | ±120 | ±120 | ±120 | ±120 |
Positioning | Tolerance | L-836.521200D | L-836.521200FD | L-836.521212D | L-836.521212FD |
|---|---|---|---|---|---|
Minimum incremental motion in X [µm] | max. | 0.3 | 0.4 | 0.24 | 0.24 |
Positioning accuracy in X, uncalibrated [µm] | max. | ±20 | ±20 | ±20 | ±20 |
Bidirectional repeatability in X [µm] | max. | 2 | 4 | 0.8 | 0.8 |
Reference switch |
| Hall effect | Hall effect | Hall effect | Hall effect |
Limit switch |
| Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN |
Integrated sensor |
| — | — | Incremental linear encoder | Incremental linear encoder |
Sensor signal |
| — | — | A/B quadrature, RS-422 | A/B quadrature, RS-422 |
Sensor signal period [µm] |
| — | — | 80 | 80 |
Sensor resolution [nm] 1) |
| — | — | 80 | 80 |
Drive properties | Tolerance | L-836.521200D | L-836.521200FD | L-836.521212D | L-836.521212FD |
|---|---|---|---|---|---|
Drive type |
| 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor |
Operating voltage [V] |
| 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 |
Nominal current, RMS [A] | typ. | 1.5 | 1.5 | 1.5 | 1.5 |
Maximum power consumption [W] |
| 7 | 7 | 8 | 8 |
Motor resolution [full steps/U] |
| 200 | 200 | 200 | 200 |
Drive force in X [N] | typ. | 75 | 75 | 75 | 75 |
Resistance phase-phase [Ω] 2) | typ. | 1.18 | 1.18 | 1.18 | 1.18 |
Inductance phase-phase [mH] |
| 0.96 | 0.96 | 0.96 | 0.96 |
Mechanical properties | Tolerance | L-836.521200D | L-836.521200FD | L-836.521212D | L-836.521212FD |
|---|---|---|---|---|---|
Permissible push force in Y [N] | max. | 50 | 50 | 50 | 50 |
Permissible push force in Z [N] | max. | 150 | 150 | 150 | 150 |
Permissible torque in θX [Nm] | max. | 15 | 15 | 15 | 15 |
Permissible torque in θY [Nm] | max. | 15 | 15 | 15 | 15 |
Permissible torque in θZ [Nm] | max. | 10 | 10 | 10 | 10 |
Holding force in X, passive [N] |
| — | — | — | — |
Moved mass in X, unloaded [g] |
| 130 | 130 | 140 | 140 |
Drive screw type |
| Ball screw | Ball screw | Ball screw | Ball screw |
Drive screw pitch [mm] |
| 1 | 1 | 1 | 1 |
Guide |
| Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide |
Overall mass [g] |
| 840 | 900 | 850 | 910 |
Material |
| Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel |
Holding brake |
| — | — | — | — |
Miscellaneous | L-836.521200D | L-836.521200FD | L-836.521212D | L-836.521212FD |
|---|---|---|---|---|
Operating temperature range [°C] | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 |
Connector | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) |
Recommended controllers/drivers | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller |
Motion | Tolerance | L-836.531200D | L-836.531200FD | L-836.531200BD | L-836.531200BFD | L-836.531212D | L-836.531212FD | L-836.531212BD | L-836.531212BFD |
|---|---|---|---|---|---|---|---|---|---|
Active axes |
| X | X | X | X | X | X | X | X |
Travel range in X [mm] |
| 100 | 100 | 100 | 100 | 100 | 100 | 100 | 100 |
Acceleration in X, unloaded [m/s2] | max. | 4 | 4 | 4 | 4 | 4 | 4 | 4 | 4 |
Maximum velocity in X, unloaded [mm/s] |
| 80 | 80 | 80 | 80 | 80 | 80 | 80 | 80 |
Straightness error in Y (straightness) [µm] | max. | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 |
Straightness error in Z (flatness) [µm] | max. | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 |
Angular error around Y (pitch) [µrad] | max. | ±180 | ±180 | ±180 | ±180 | ±180 | ±180 | ±180 | ±180 |
Angular error around Z (yaw) [µrad] | max. | ±180 | ±180 | ±180 | ±180 | ±180 | ±180 | ±180 | ±180 |
Positioning | Tolerance | L-836.531200D | L-836.531200FD | L-836.531200BD | L-836.531200BFD | L-836.531212D | L-836.531212FD | L-836.531212BD | L-836.531212BFD |
|---|---|---|---|---|---|---|---|---|---|
Minimum incremental motion in X [µm] | max. | 0.75 | 0.75 | 0.75 | 0.75 | 0.24 | 0.24 | 0.24 | 0.24 |
Positioning accuracy in X, uncalibrated [µm] | max. | ±25 | ±25 | ±25 | ±25 | ±25 | ±25 | ±25 | ±25 |
Bidirectional repeatability in X [µm] | max. | 4 | 6 | 4 | 6 | 0.8 | 0.8 | 0.8 | 0.8 |
Reference switch |
| Hall effect | Hall effect | Hall effect | Hall effect | Hall effect | Hall effect | Hall effect | Hall effect |
Limit switch |
| Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN |
Integrated sensor |
| — | — | — | — | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder |
Sensor signal |
| — | — | — | — | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 |
Sensor signal period [µm] |
| — | — | — | — | 80 | 80 | 80 | 80 |
Sensor resolution [nm] 1) |
| — | — | — | — | 80 | 80 | 80 | 80 |
Drive properties | Tolerance | L-836.531200D | L-836.531200FD | L-836.531200BD | L-836.531200BFD | L-836.531212D | L-836.531212FD | L-836.531212BD | L-836.531212BFD |
|---|---|---|---|---|---|---|---|---|---|
Drive type |
| 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor |
Operating voltage [V] |
| 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 |
Nominal current, RMS [A] | typ. | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 |
Maximum power consumption [W] |
| 7 | 7 | 7 | 7 | 8 | 8 | 8 | 8 |
Motor resolution [full steps/U] |
| 200 | 200 | 200 | 200 | 200 | 200 | 200 | 200 |
Drive force in X [N] | typ. | 75 | 75 | 75 | 75 | 75 | 75 | 75 | 75 |
Resistance phase-phase [Ω] 2) | typ. | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 |
Inductance phase-phase [mH] |
| 0.96 | 0.96 | 0.96 | 0.96 | 0.96 | 0.96 | 0.96 | 0.96 |
Mechanical properties | Tolerance | L-836.531200D | L-836.531200FD | L-836.531200BD | L-836.531200BFD | L-836.531212D | L-836.531212FD | L-836.531212BD | L-836.531212BFD |
|---|---|---|---|---|---|---|---|---|---|
Permissible push force in Y [N] | max. | 50 | 50 | 50 | 50 | 50 | 50 | 50 | 50 |
Permissible push force in Z [N] | max. | 150 | 150 | 150 | 150 | 150 | 150 | 150 | 150 |
Permissible torque in θX [Nm] | max. | 15 | 15 | 15 | 15 | 15 | 15 | 15 | 15 |
Permissible torque in θY [Nm] | max. | 15 | 15 | 15 | 15 | 15 | 15 | 15 | 15 |
Permissible torque in θZ [Nm] | max. | 10 | 10 | 10 | 10 | 10 | 10 | 10 | 10 |
Holding force in X, passive [N] |
| — | — | 300 | 300 | — | — | 300 | 300 |
Moved mass in X, unloaded [g] |
| 130 | 130 | 130 | 130 | 140 | 140 | 140 | 140 |
Drive screw type |
| Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw |
Drive screw pitch [mm] |
| 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
Guide |
| Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide |
Overall mass [g] |
| 900 | 960 | 960 | 1010 | 910 | 970 | 970 | 1020 |
Material |
| Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel |
Holding brake |
| — | — | Electromagnetic safety brake | Electromagnetic safety brake | — | — | Electromagnetic safety brake | Electromagnetic safety brake |
Miscellaneous | L-836.531200D | L-836.531200FD | L-836.531200BD | L-836.531200BFD | L-836.531212D | L-836.531212FD | L-836.531212BD | L-836.531212BFD |
|---|---|---|---|---|---|---|---|---|
Operating temperature range [°C] | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 |
Connector | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) |
Recommended controllers/drivers | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller |
Motion | Tolerance | L-836.541200D | L-836.541200FD | L-836.541200BD | L-836.541200BFD | L-836.541212D | L-836.541212FD | L-836.541212BD | L-836.541212BFD |
|---|---|---|---|---|---|---|---|---|---|
Active axes |
| X | X | X | X | X | X | X | X |
Travel range in X [mm] |
| 150 | 150 | 150 | 150 | 150 | 150 | 150 | 150 |
Acceleration in X, unloaded [m/s2] | max. | 4 | 4 | 4 | 4 | 4 | 4 | 4 | 4 |
Maximum velocity in X, unloaded [mm/s] |
| 80 | 80 | 80 | 80 | 80 | 80 | 80 | 80 |
Straightness error in Y (straightness) [µm] | max. | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 |
Straightness error in Z (flatness) [µm] | max. | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 |
Angular error around Y (pitch) [µrad] | max. | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 |
Angular error around Z (yaw) [µrad] | max. | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 |
Positioning | Tolerance | L-836.541200D | L-836.541200FD | L-836.541200BD | L-836.541200BFD | L-836.541212D | L-836.541212FD | L-836.541212BD | L-836.541212BFD |
|---|---|---|---|---|---|---|---|---|---|
Minimum incremental motion in X [µm] | max. | 0.75 | 0.75 | 0.75 | 0.75 | 0.24 | 0.24 | 0.24 | 0.24 |
Positioning accuracy in X, uncalibrated [µm] | max. | ±32 | ±32 | ±32 | ±32 | ±32 | ±32 | ±32 | ±32 |
Bidirectional repeatability in X [µm] | max. | 4 | 6 | 4 | 6 | 0.8 | 0.8 | 0.8 | 0.8 |
Reference switch |
| Hall effect | Hall effect | Hall effect | Hall effect | Hall effect | Hall effect | Hall effect | Hall effect |
Limit switch |
| Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN |
Integrated sensor |
| — | — | — | — | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder |
Sensor signal |
| — | — | — | — | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 |
Sensor signal period [µm] |
| — | — | — | — | 80 | 80 | 80 | 80 |
Sensor resolution [nm] 1) |
| — | — | — | — | 80 | 80 | 80 | 80 |
Drive properties | Tolerance | L-836.541200D | L-836.541200FD | L-836.541200BD | L-836.541200BFD | L-836.541212D | L-836.541212FD | L-836.541212BD | L-836.541212BFD |
|---|---|---|---|---|---|---|---|---|---|
Drive type |
| 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor |
Operating voltage [V] |
| 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 |
Nominal current, RMS [A] | typ. | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 |
Maximum power consumption [W] |
| 7 | 7 | 7 | 7 | 8 | 8 | 8 | 8 |
Motor resolution [full steps/U] |
| 200 | 200 | 200 | 200 | 200 | 200 | 200 | 200 |
Drive force in X [N] | typ. | 75 | 75 | 75 | 75 | 75 | 75 | 75 | 75 |
Resistance phase-phase [Ω] 2) | typ. | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 |
Inductance phase-phase [mH] |
| 0.96 | 0.96 | 0.96 | 0.96 | 0.96 | 0.96 | 0.96 | 0.96 |
Mechanical properties | Tolerance | L-836.541200D | L-836.541200FD | L-836.541200BD | L-836.541200BFD | L-836.541212D | L-836.541212FD | L-836.541212BD | L-836.541212BFD |
|---|---|---|---|---|---|---|---|---|---|
Permissible push force in Y [N] | max. | 50 | 50 | 50 | 50 | 50 | 50 | 50 | 50 |
Permissible push force in Z [N] | max. | 150 | 150 | 150 | 150 | 150 | 150 | 150 | 150 |
Permissible torque in θX [Nm] | max. | 15 | 15 | 15 | 15 | 15 | 15 | 15 | 15 |
Permissible torque in θY [Nm] | max. | 15 | 15 | 15 | 15 | 15 | 15 | 15 | 15 |
Permissible torque in θZ [Nm] | max. | 10 | 10 | 10 | 10 | 10 | 10 | 10 | 10 |
Holding force in X, passive [N] |
| — | — | 300 | 300 | — | — | 300 | 300 |
Moved mass in X, unloaded [g] |
| 130 | 130 | 130 | 130 | 140 | 140 | 140 | 140 |
Drive screw type |
| Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw |
Drive screw pitch [mm] |
| 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
Guide |
| Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide |
Overall mass [g] |
| 1020 | 1080 | 1080 | 1130 | 1030 | 1090 | 1090 | 1140 |
Material |
| Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel |
Holding brake |
| — | — | Electromagnetic safety brake | Electromagnetic safety brake | — | — | Electromagnetic safety brake | Electromagnetic safety brake |
Miscellaneous | L-836.541200D | L-836.541200FD | L-836.541200BD | L-836.541200BFD | L-836.541212D | L-836.541212FD | L-836.541212BD | L-836.541212BFD |
|---|---|---|---|---|---|---|---|---|
Operating temperature range [°C] | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 |
Connector | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) |
Recommended controllers/drivers | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller |
Motion | Tolerance | L-836.551200D | L-836.551200FD | L-836.551200BD | L-836.551200BFD | L-836.551212D | L-836.551212FD | L-836.551212BD | L-836.551212BFD |
|---|---|---|---|---|---|---|---|---|---|
Active axes |
| X | X | X | X | X | X | X | X |
Travel range in X [mm] |
| 200 | 200 | 200 | 200 | 200 | 200 | 200 | 200 |
Acceleration in X, unloaded [m/s2] | max. | 4 | 4 | 4 | 4 | 4 | 4 | 4 | 4 |
Maximum velocity in X, unloaded [mm/s] |
| 80 | 80 | 80 | 80 | 80 | 80 | 80 | 80 |
Straightness error in Y (straightness) [µm] | max. | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 |
Straightness error in Z (flatness) [µm] | max. | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 | ±3 |
Angular error around Y (pitch) [µrad] | max. | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 |
Angular error around Z (yaw) [µrad] | max. | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 | ±200 |
Positioning | Tolerance | L-836.551200D | L-836.551200FD | L-836.551200BD | L-836.551200BFD | L-836.551212D | L-836.551212FD | L-836.551212BD | L-836.551212BFD |
|---|---|---|---|---|---|---|---|---|---|
Minimum incremental motion in X [µm] | max. | 0.75 | 0.75 | 0.75 | 0.75 | 0.24 | 0.24 | 0.24 | 0.24 |
Positioning accuracy in X, uncalibrated [µm] | max. | ±50 | ±50 | ±50 | ±50 | ±50 | ±50 | ±50 | ±50 |
Bidirectional repeatability in X [µm] | max. | 4 | 6 | 4 | 6 | 0.8 | 0.8 | 0.8 | 0.8 |
Reference switch |
| Hall effect | Hall effect | Hall effect | Hall effect | Hall effect | Hall effect | Hall effect | Hall effect |
Limit switch |
| Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN |
Integrated sensor |
| — | — | — | — | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder |
Sensor signal |
| — | — | — | — | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 |
Sensor signal period [µm] |
| — | — | — | — | 80 | 80 | 80 | 80 |
Sensor resolution [nm] 1) |
| — | — | — | — | 80 | 80 | 80 | 80 |
Drive properties | Tolerance | L-836.551200D | L-836.551200FD | L-836.551200BD | L-836.551200BFD | L-836.551212D | L-836.551212FD | L-836.551212BD | L-836.551212BFD |
|---|---|---|---|---|---|---|---|---|---|
Drive type |
| 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor |
Operating voltage [V] |
| 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 | 24 to 48 |
Nominal current, RMS [A] | typ. | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 | 1.5 |
Maximum power consumption [W] |
| 7 | 7 | 7 | 7 | 8 | 8 | 8 | 8 |
Motor resolution [full steps/U] |
| 200 | 200 | 200 | 200 | 200 | 200 | 200 | 200 |
Drive force in X [N] | typ. | 75 | 75 | 75 | 75 | 75 | 75 | 75 | 75 |
Resistance phase-phase [Ω] 2) | typ. | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 | 1.18 |
Inductance phase-phase [mH] |
| 0.96 | 0.96 | 0.96 | 0.96 | 0.96 | 0.96 | 0.96 | 0.96 |
Mechanical properties | Tolerance | L-836.551200D | L-836.551200FD | L-836.551200BD | L-836.551200BFD | L-836.551212D | L-836.551212FD | L-836.551212BD | L-836.551212BFD |
|---|---|---|---|---|---|---|---|---|---|
Permissible push force in Y [N] | max. | 50 | 50 | 50 | 50 | 50 | 50 | 50 | 50 |
Permissible push force in Z [N] | max. | 150 | 150 | 150 | 150 | 150 | 150 | 150 | 150 |
Permissible torque in θX [Nm] | max. | 15 | 15 | 15 | 15 | 15 | 15 | 15 | 15 |
Permissible torque in θY [Nm] | max. | 15 | 15 | 15 | 15 | 15 | 15 | 15 | 15 |
Permissible torque in θZ [Nm] | max. | 10 | 10 | 10 | 10 | 10 | 10 | 10 | 10 |
Holding force in X, passive [N] |
| — | — | 300 | 300 | — | — | 300 | 300 |
Moved mass in X, unloaded [g] |
| 130 | 130 | 130 | 130 | 140 | 140 | 140 | 140 |
Drive screw type |
| Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw |
Drive screw pitch [mm] |
| 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
Guide |
| Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide |
Overall mass [g] |
| 1150 | 1210 | 1210 | 1260 | 1160 | 1220 | 1220 | 1270 |
Material |
| Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel | Aluminum, black anodized; stainless steel |
Holding brake |
| — | — | Electromagnetic safety brake | Electromagnetic safety brake | — | — | Electromagnetic safety brake | Electromagnetic safety brake |
Miscellaneous | L-836.551200D | L-836.551200FD | L-836.551200BD | L-836.551200BFD | L-836.551212D | L-836.551212FD | L-836.551212BD | L-836.551212BFD |
|---|---|---|---|---|---|---|---|---|
Operating temperature range [°C] | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 | 5 to 40 |
Connector | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) | HD D-sub 26 (m) |
Recommended controllers/drivers | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | C-663 G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller | G-901 G-910 ACS modular controller |
1) 250x interpolated
2) Tolerance: +/- 10 %
At PI, technical data is specified at 22 ±3 °C. Unless otherwise stated, the values are for unloaded conditions. Some properties are interdependent. The designation "typ." indicates a statistical average for a property; it does not indicate a guaranteed value for every product supplied. During the final inspection of a product, only selected properties are analyzed, not all. Please note that some product characteristics may deteriorate with increasing operating time.
L-836 Linear Stage with Stepper Motor
Ask for a free quote on quantities required, prices, and lead times or describe your desired modification.
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 25 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 25 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 50 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 50 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 75 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 75 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 100 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 100 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 100 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; electromagnetic safety brake
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 100 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; electromagnetic safety brake; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 150 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 150 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 150 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; electromagnetic safety brake
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 150 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; electromagnetic safety brake; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 200 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 200 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 200 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; electromagnetic safety brake
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 200 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; electromagnetic safety brake; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 25 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 25 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 50 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 50 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 75 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 75 mm travel range; 150 N load capacity; 40 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 100 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 100 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 100 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; electromagnetic safety brake
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 100 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; electromagnetic safety brake; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 150 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 150 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 150 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; electromagnetic safety brake
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 150 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; electromagnetic safety brake; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 200 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 200 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; folded drivetrain
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 200 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; electromagnetic safety brake
Stackable, highly compact, universal linear stage; 2-phase stepper motor; 200 mm travel range; 150 N load capacity; 80 mm/s maximum velocity; ball screw; incremental linear encoder, 80 µm sensor signal period, A/B quadrature, RS-422; electromagnetic safety brake; folded drivetrain
Mounting bracket for vertical mounting of L-836 stages with 25 mm travel range; anodized aluminum alloy; 135 mm long; mounting hardware included
Mounting bracket for vertical mounting of L-836 stages with 50 mm, 75 mm, and 100 mm travel range; anodized aluminum alloy; 197.5 mm long; mounting hardware included